
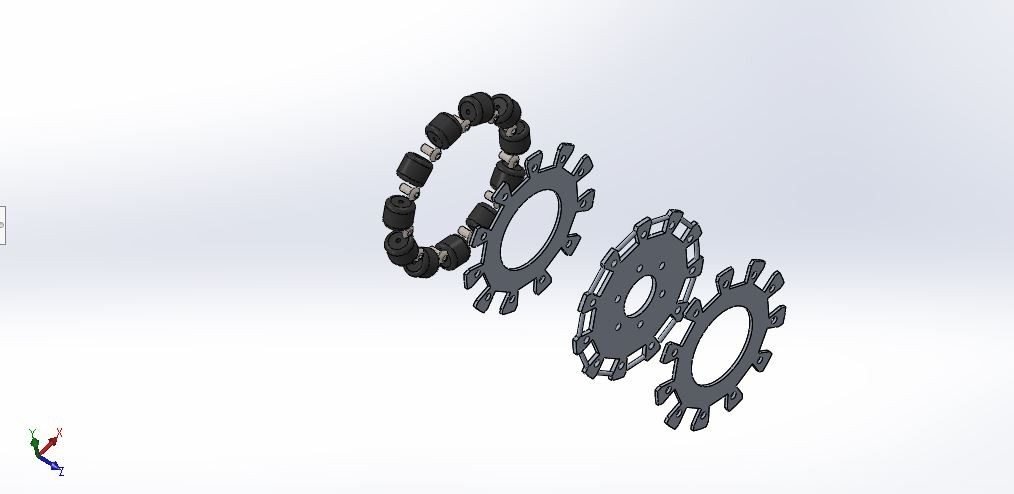
Most wheels can only roll forward and backward. An omni wheel (also called a poly wheel) has small rollers mounted around its rim, with their axes at right angles to the wheel’s axis. The wheel can be driven with full force in its rolling direction, yet it can also slide sideways easily on its rollers. When three or four omni wheels are combined, a robot or cart can move in any direction and rotate on the spot without steering. This is called holonomic motion, and it is widely used in mobile robots, warehouse carts and robot competitions. This project designs two omni wheels and studies them with two engineering plastics.
Omni Wheels vs Mecanum Wheels
Omni wheels and mecanum wheels both allow sideways motion. In an omni wheel the rollers are at 90° to the wheel axis, and the wheels are usually arranged at angles to each other on the robot. In a mecanum wheel the rollers sit at 45°, and the wheels are mounted in a normal four-wheel layout. Omni wheels are simpler to make and are popular for small robots, conveyors and transfer tables.
About the Project
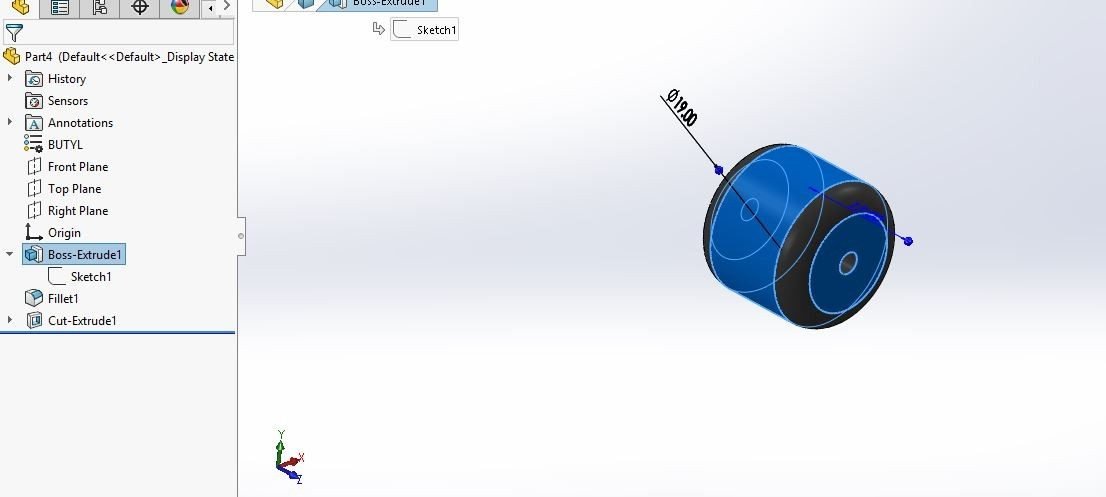
Two omni wheel designs with different hub and roller arrangements are modelled part by part in SolidWorks: hub plates, rollers, roller shafts and the complete assemblies. Both designs are analysed in ANSYS Workbench:
- Static structural analysis: the hub is fixed and a radial load is applied on the rollers (145 N and 200 N load cases), to find deformation, stress, strain and safety factor.
- Modal analysis: the first six natural frequencies of each design.
Two materials are compared: nylon, the usual material for omni wheel parts, and polybutylene terephthalate (PBT), a stiff, tough engineering plastic.


Software Used
- SolidWorks: hub, roller and assembly modelling
- ANSYS Workbench: static structural and modal analysis
Analysis Setup


The full static and modal results for both designs and both materials, with the comparison and final recommendation, are provided in the project report and explained in the class.
Real-World Applications
- Mobile robots: holonomic robots for research, education and competitions.
- Warehouse and logistics: carts and transfer tables that move in any direction.
- Medical and service robots: compact robots that manoeuvre in tight spaces.
- Material handling: conveyor transfer units that turn parcels and boxes.
Key Concepts Covered
- Holonomic motion: moving in any direction without steering.
- Roller arrangement: how roller layout affects smooth rolling and load sharing.
- Engineering plastics: nylon and PBT for lightweight wheels.
- Modal analysis: checking vibration behaviour of rotating parts.
Project Workflow
- Study omni and mecanum wheels and their applications.
- Model the hub plates, rollers and shafts for two designs in SolidWorks.
- Assemble both wheels and create exploded views.
- Apply loads in ANSYS and run static and modal analysis for nylon and PBT.
- Compare designs and materials in the report.
Why This Project Matters
Omni-directional mobility is a key technology in modern robotics and automation. This project is a great final-year choice for mechanical, mechatronics and robotics students.
Related Projects
Explore more design and analysis projects on similar topics:
- Design and Analysis of a Versatile Drone and Rover for Crop Care and Farm Optimization (SolidWorks and ANSYS)
- Stair Climbing Robot Trolley Design and Analysis – Steel, SS 304, SS 316 and Al-7075
- Six-Leg Robot with C-Shaped Legs – Design in Creo and Body Structural Analysis
- Pipeline Inspection Robot Design: Self-Adjusting Wheeled Mechanism for 140–200 mm Pipes (Creo)
What You Get
- Design files: SolidWorks models of both omni wheel designs: hub plates, rollers, shafts and full assemblies (with STEP files)
- Analysis files: ANSYS Workbench static structural and modal analysis files for both designs and both materials
- Project document: complete report with methodology, results and conclusion
- Class explanation: a session that explains what was done in the project, step by step, so you can understand and present it confidently
Who Is This Project For?
This project suits B.Tech and B.E. final year students, diploma students looking for a strong design and analysis project, and M.Tech students who need a base model they can extend for their thesis. It is also useful for anyone who wants to learn omni-directional wheel design, static and modal analysis in ANSYS on a real engineering problem instead of a textbook example.
Frequently Asked Questions
What is an omni wheel?
An omni wheel has small rollers around its rim at right angles to the wheel axis, so it can roll forward normally and also slide sideways on its rollers.
What is holonomic motion?
It is the ability of a vehicle or robot to move in any direction and rotate on the spot without steering, which omni wheels make possible.
Which materials are studied?
Nylon and polybutylene terephthalate (PBT) are compared for both wheel designs.
What analyses are done?
Static structural analysis under radial loads and modal analysis for the first six natural frequencies.
Get the Omni Wheel Project
Want this project for your final year, mini project or M.Tech work? Message us with your university, branch and deadline, and we will share the exact scope, files and report format.
Enquire about this project on WhatsApp or use the enquiry form on our home page. Browse more mechanical projects or 60+ mechanical engineering project ideas.
Interested in this project? Get the details, files and guidance from our team.
Enquire on WhatsApp